Robotics & Controls Portfolio

Clément Dumeril.

I work on model-based control and learning for robots.

MEng student at UC Berkeley (2026-2027), in control of robotic and autonomous systems. Before that, mechanical engineering at Arts et Metiers: CAD, FEA, simulation, machining, vibrations.

Academic context

UC Berkeley Mechanical Engineering - Robotics
Arts et Metiers Industrial mechanics

02. Relevant Experience

UC Berkeley EECS logo

Graduate Researcher @ UC Berkeley, Agile Robotics and Perception Lab (ARPL)

Advisor: Prof. Giuseppe Loianno. Learning-based control for aerial robotics.

Aug 2026 - Present
  • Developing learning-accelerated, energy-aware nonlinear MPC for small fixed-wing aerial robots.
  • Combining learned warm starts, neural approximations and reinforcement learning for real-time trajectory optimization.
Polytechnia logo

Co-founder @ Polytechnia

Engineering consultancy for hardware projects.

May 2026 - August 2026
  • Won the firm's first client contracts.
  • Built the fan simulation package (OpenFOAM, Code_Aster) on a 2-node Linux MPI cluster I set up.
LCPI logo

Research Assistant @ LCPI

Product design and innovation lab, Arts et Metiers.

September 2025 - June 2026
  • Fine-tuned a vision-language model to extract engineering data from the sketch and text of industrial idea sheets: ~53% to 76% accuracy.
  • Compared it with classical computer vision and YOLO.
AMJE logo

Commercial & Project Director @ AMJE

Arts et Metiers Junior Etude, Paris.

Mar 2025 - May 2026
  • Led a 5-engineer team on a $75k Ministry of the Interior R&D mission: a device that stops vehicles without puncturing tires. CAD, simulation, electromechanical and hydraulic integration, 150+ fabrication hours. Alten Prize 2025.
  • Board member for sales: record $350k annual revenue; trained 30 student project managers.
Air Flow logo

Project Manager - Engineering Consulting @ AIR FLOW

Part-time mission on railway cooling.

June 2025 - May 2026
  • Led the team on liquid-nitrogen cooling for a mobile railway setting: thermal studies, heat-exchanger geometry and risk analysis.
  • Delivered recommendations on safety, performance and compliance.
TechWave and OPEO logo

Engineering Intern @ Groupe Techwave

AI integration at an industrial mechanics and electronics company.

May 2025 - July 2025
  • Built an LLM assistant (retrieval over engineering documents) for OPEO's consultants.
  • Contributed to securing EUR 30k in BPI funding through the Accelerateur PME program.

03. All Projects

Everything else, by theme. Pick a card for details.

Robotics & ML

Control, learning and perception.

Simulation

Solvers, FEA and CFD, checked against data.

Software & AI tools

Side builds and applied AI.

Mechanical engineering

Earlier Arts et Metiers projects.

Robotics / Reinforcement Learning / Simulation / Python

Fall 2026

Fixed-Wing: SAC Policy vs. PID in an L2F-Style Simulator

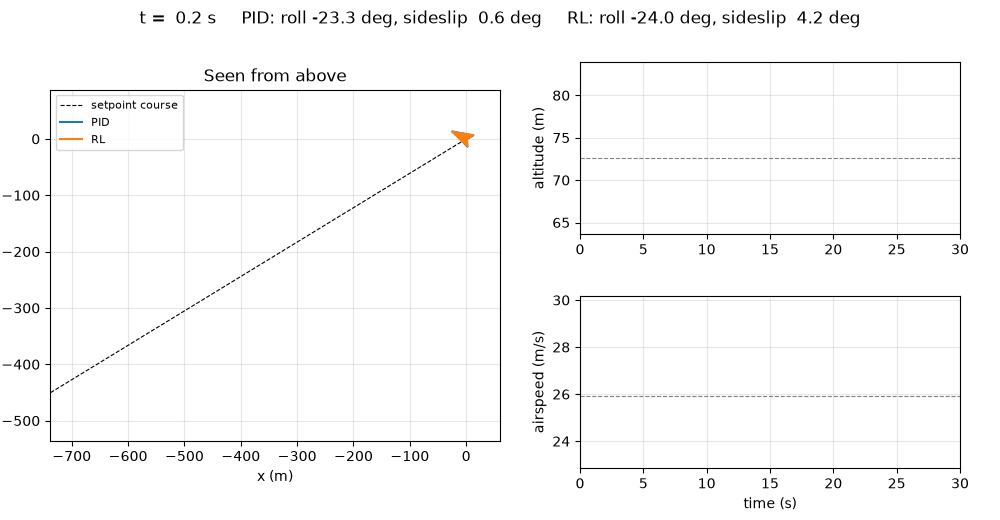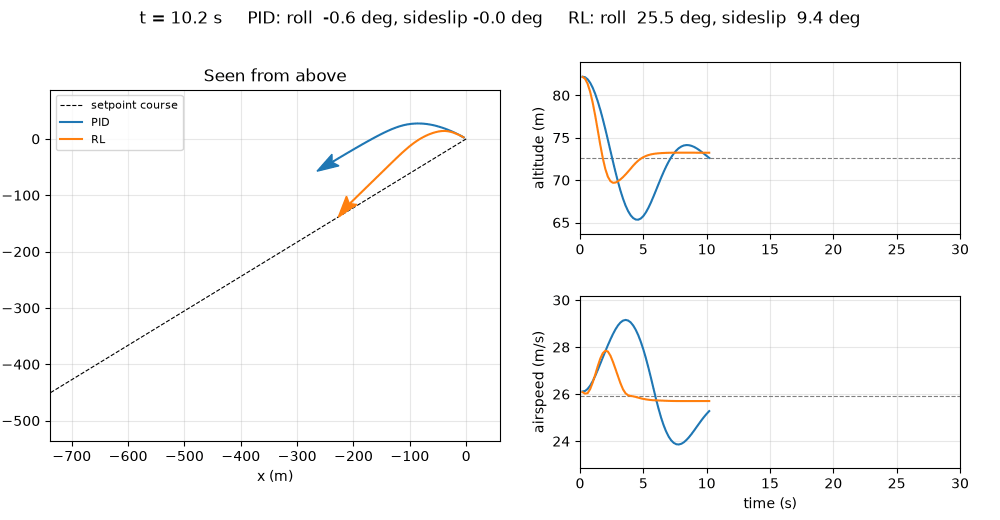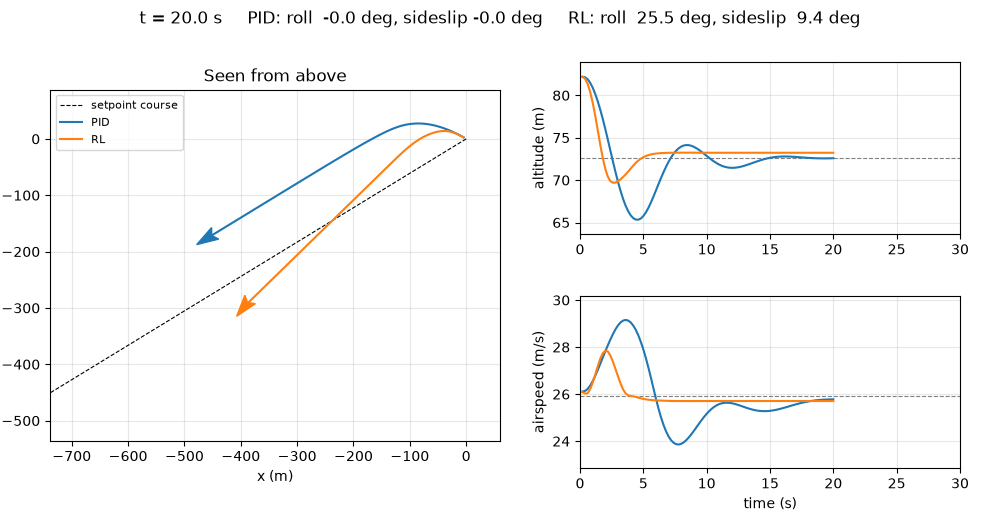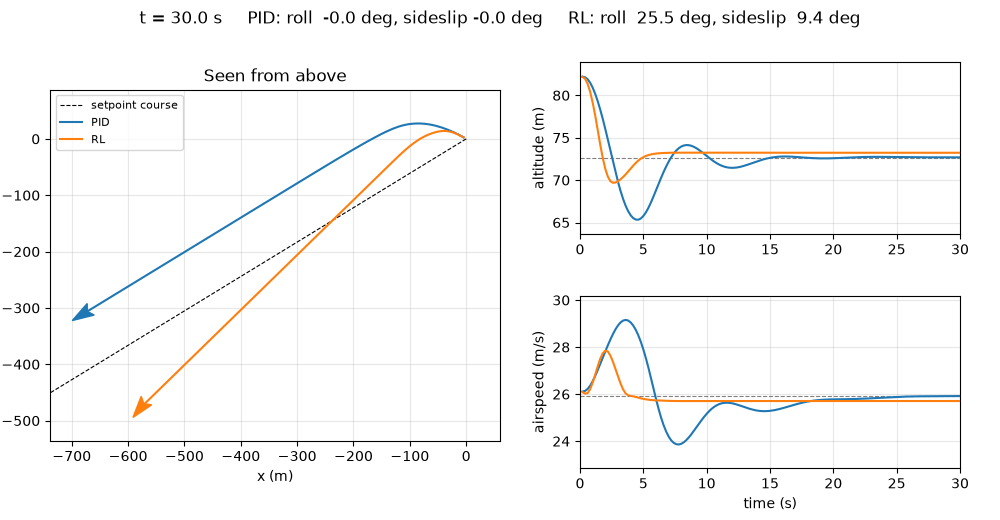
MEng capstone at ARPL (Prof. Loianno): a NumPy fixed-wing simulator on the structure of L2F from RLtools (6-DOF, RK4, gusts, thermals, Dryden turbulence, actuator lag, trim solver) and a Gymnasium task in which a SAC policy (stable-baselines3, 1M steps on Savio) flies the control surfaces. On 100 test flights SAC completes 98 against 100 for a PID, with a lower airspeed error (0.14 vs. 0.37 m/s), but it settles in a 9-degree sideslip that I traced to the reward. A curriculum run then failed because exploration noise alone saturated the cost; the reward now penalizes sideslip and distance to trim, and 3-seed runs with wind are on Savio.

  • Python / NumPy
  • SAC (stable-baselines3)
  • RK4 flight dynamics
  • Savio (Slurm)
Fixed-Wing SAC vs. PID preview

04. Contact

Get in touch.

I'm looking for robotics, controls and ML roles from May 2027. Email is the fastest way to reach me.